People
Principle Investigator
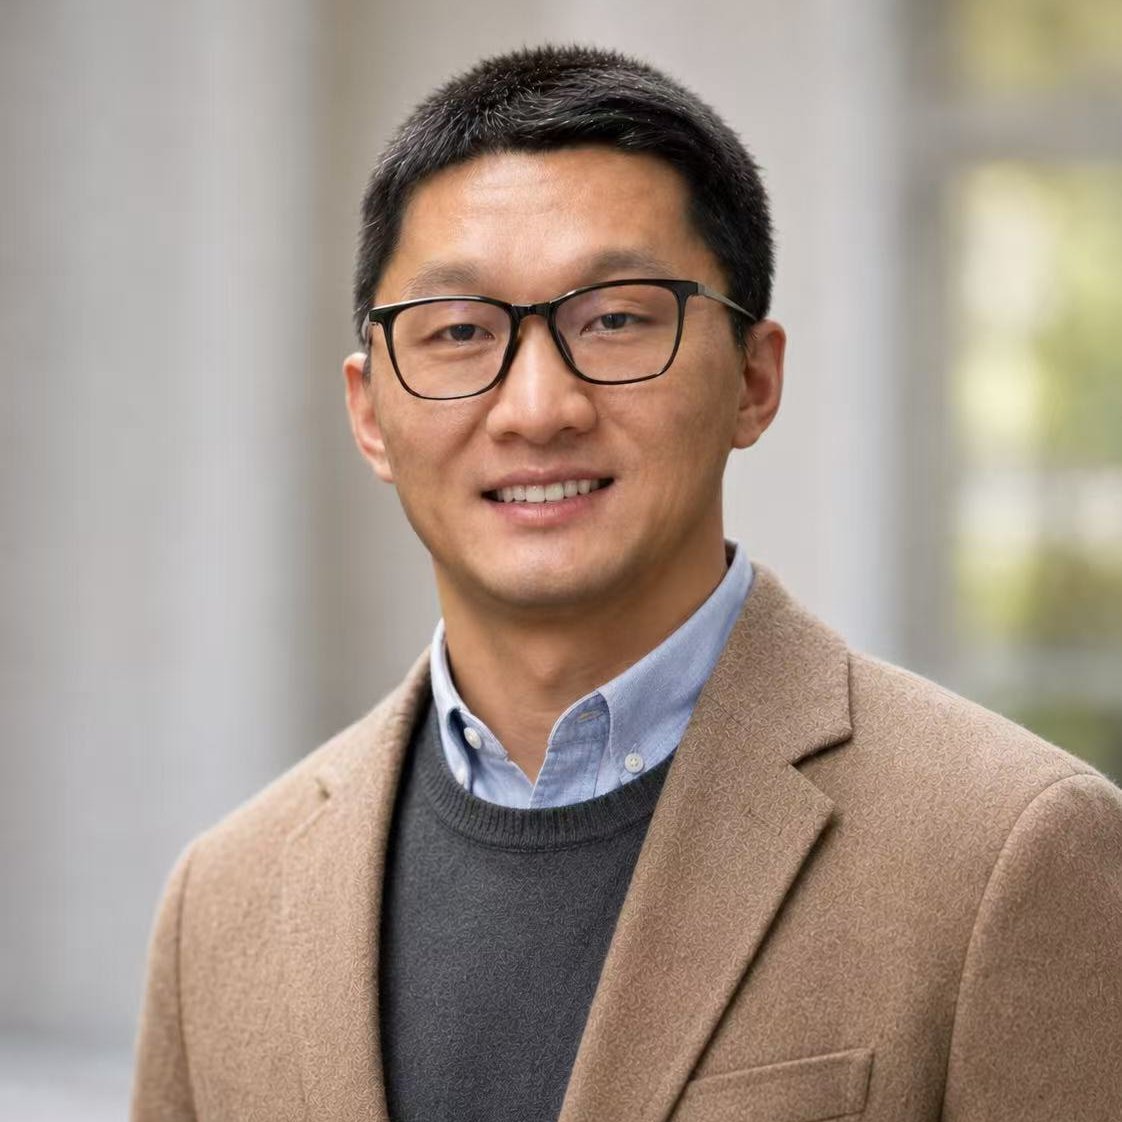
Daoguan Ning
Assistant Professor
Department of Mechanical Engineering and Engineering Science
University of North Carolina, Charlotte
Graduate Students
Adaptive Robot Policies
How can robot policies adapt dynamically at inference time to handle new tasks, environments, and embodiment variations?
Interactive World Models
How can structured world models help agents anticipate spatial, temporal, and physical interactions before acting?
Proactive Self-Improvement
How can agents verify and learn from their own predictions to improve continually with minimal human supervision?
Undergraduate Students
Proactive Self-Improvement
How can agents verify and learn from their own predictions to improve continually with minimal human supervision?
Research Staff
Proactive Self-Improvement
How can agents verify and learn from their own predictions to improve continually with minimal human supervision?
Visiting Scholars
Adaptive Robot Policies
How can robot policies adapt dynamically at inference time to handle new tasks, environments, and embodiment variations?
Alumni
© 2026 EMC2 Lab. All rights reserved.